Mostafa Lotfy
Building robots that do their best to understand the world and adapt to it
About Me
A computer engineer specializing in robot perception, state estimation, and control. My work spans SLAM, visual-inertial odometry, sensor fusion, and computer vision through to classical control and reinforcement learning.
Education

Northeastern University
MS in Electrical and Computer Engineering — Robotics
Sep 2024 — Dec 2026

The American University in Cairo
BS in Computer Engineering; Minor in Mathematics
Sep 2019 — May 2024

The University of Edinburgh
Visiting Student — Informatics
Sep 2022 — Dec 2022
Research
Perception, estimation, control, and human-robot interaction
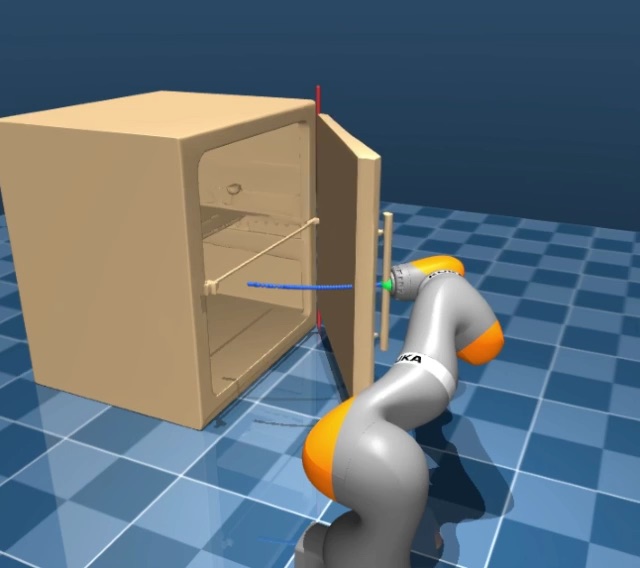
Do Your Best, Estimate the Rest
Online Mechanics Identification for Adaptive Articulated-Object Manipulation
A robot arm opens doors, lids, and drawers it has never seen and identifies their mechanics (mass, friction, damping, stiffness) online, during the task, from its own sensing alone. What kinds of mechanics exist is learned offline; which mechanics this object has is estimated online by an exact Bayesian filter.


Apps & Platforms
Apps and platforms built outside the lab


Publications
Cyberscape: A Novel Generative AI-Based Framework for Multi-Robot Mission Planning
Y. Abuzied, Z. Noureddin, M. Abdelkhalik, A. Sayed, I. Gohar, F. Mossaad, M. El-Leithy, M. Ibrahim, T. Elbatt, M. Abdelsalam
IEEE SAMI 2026 · 2026
A Coupled-Body EKF for Visual Inertial State Estimation Enabling Closed Loop Control of Morphing Wing Aerial Robots
M. Ibrahim, B. Gupta, T. Liu, A. Salagame, M. Ramezani, A. Ramezani
RA-L · 2026
Immersive Platform for VR-Driven Robotics with a Novel Cloud Framework for Remote Teleoperation and Telepresence
M. Ibrahim, A. Zaman, M. Mahmoudi, M. ElLeithy, N. ElSayed, M. Abdelsalam, E. Veas
TVCG · 2026
Experience
Currently

Northeastern University
Nov 2024 — PresentBoston, MA
Researcher
May 2026 — PresentHutchinson Group
Working under Prof. Seth Hutchinson and postdoctoral researcher Dr. Riddhi Laha to develop a smarter perception system for articulation manipulation and control. This work is in collaboration with Prof. Hanumant Singh
Researcher
Nov 2024 — May 2026Silicon Synapse Lab (lab relocated to UIUC)
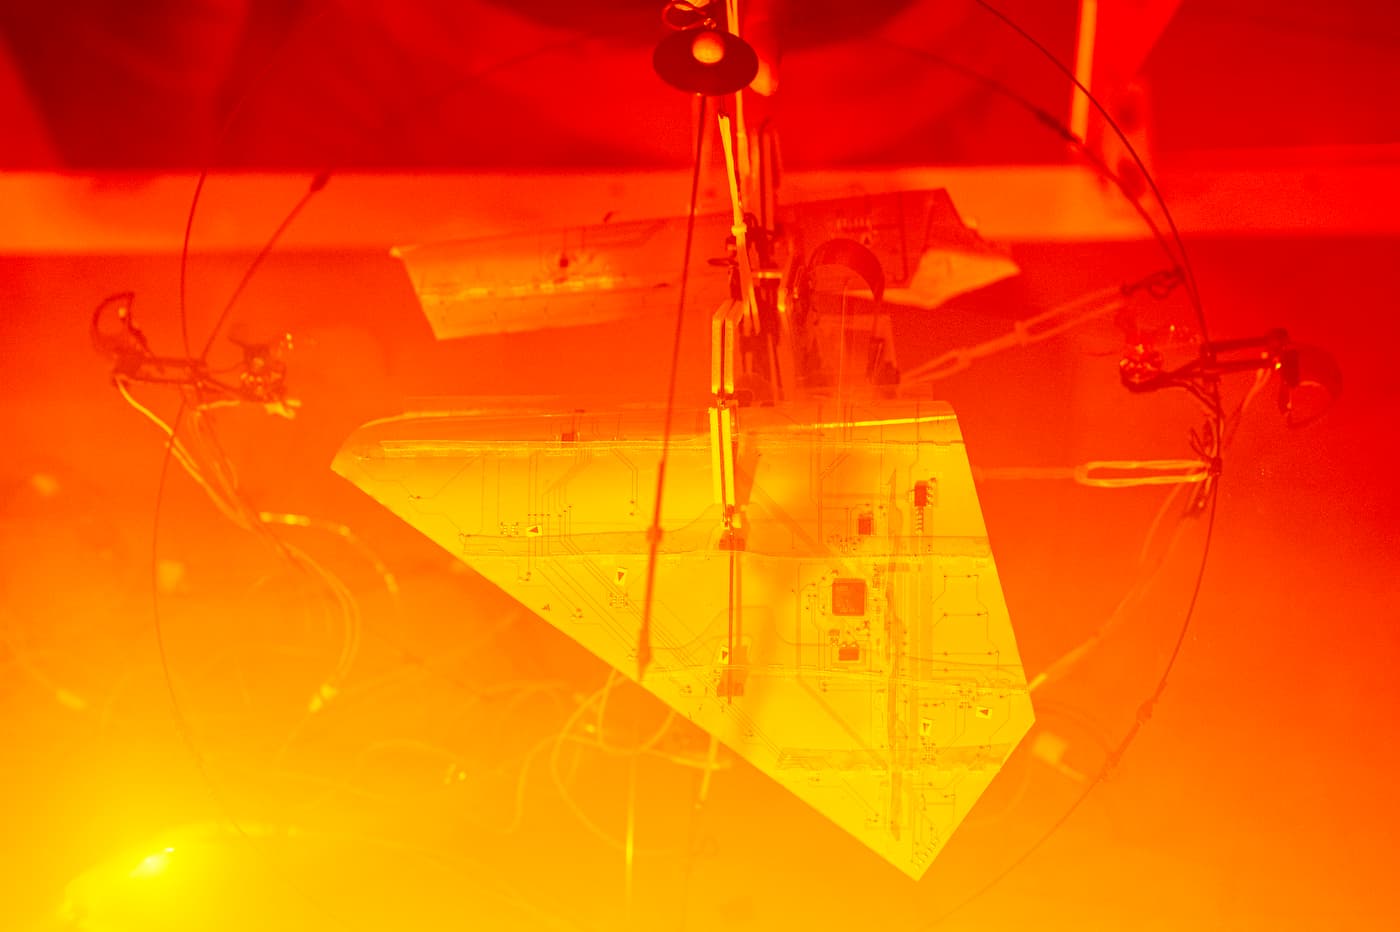
Worked under Prof. Alireza Ramezani on a bio-inspired flapping robot project, focusing on state estimation and control to enable closed-loop flight. Improved the robot's simulation model in MuJoCo.
Teaching Assistant
Sep 2026 — PresentEECE5554 — Robotics Sensing & Navigation
Lead lab sessions and office hours for Prof. Hanumant Singh's graduate course on sensing for navigation, covering IMU and magnetometer calibration, GNSS positioning and dead reckoning, and LiDAR-based SLAM. Guide students through hardware data collection on the course sensor rigs and review their lab reports.
Graduate Student Ambassador
Sep 2026 — PresentCollege of Engineering
Represent the College of Engineering to prospective and admitted graduate students. Lead information sessions and admitted-student panels, and advise applicants one-on-one on research fit, funding, and life in the program.
Previously

Senior Projects Mentor
Sep 2024 — Jun 2026The American University in Cairo · Cairo, Egypt
Supervised senior robotics projects, including an LLM-guided ground-aerial coordination framework and a swarm control system. Provided technical and strategic guidance to optimize collaboration between autonomous robots for fleet management.

Research Scientist
Jun 2024 — Dec 2024TU Graz & Know Center GmbH · Human Centered Computing Lab · Graz, Austria (Seasonal)
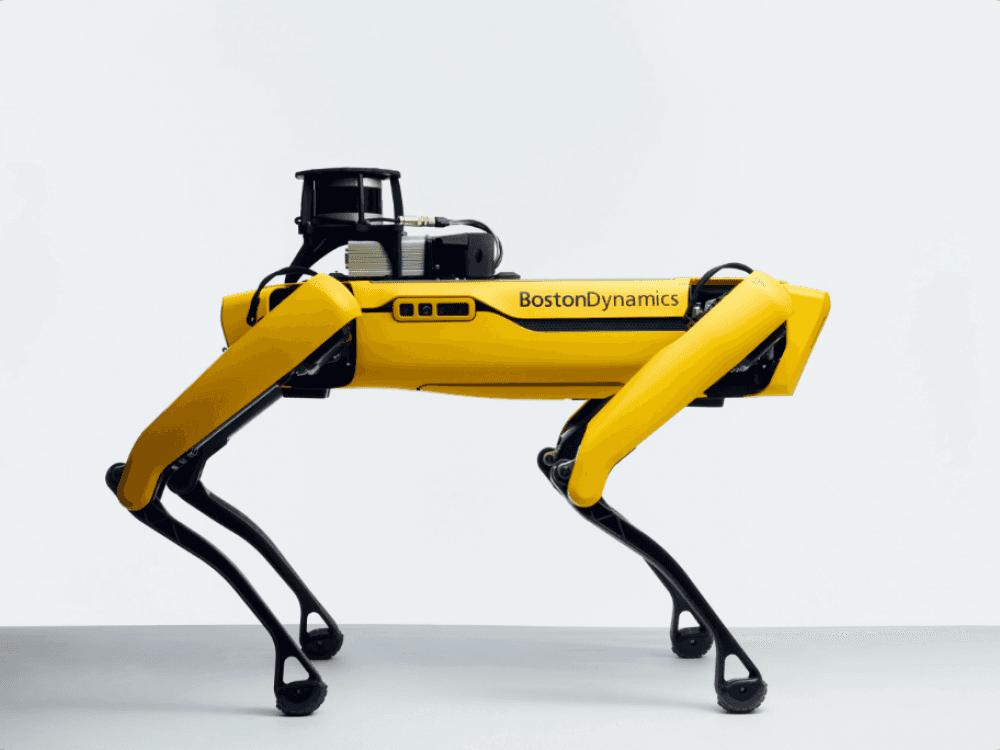
Developed telepresence systems integrating VR with quadruped robots and drones, enabling immersive control and real-time feedback. Designed and implemented a cloud-based communication framework for low-latency multi-robot operation.

R&D Intern
Sep 2023 — May 2024Siemens EDA · Cairo, Egypt
Created tools for digital twin systems, automating communication for real-time simulation and deployment. Focused on integrating drones and autonomous vehicles in mission-critical environments.

AI Intern
Jul 2023 — Oct 2023Nethermind · London, UK
Engineered solutions for Ethereum staking by refining secret-sharing algorithms. Optimized generative models for querying transaction databases and developed liquid neural networks for market trend analysis.

AI Intern
Jun 2022 — Aug 2022Benya Group · Cairo, Egypt
Built AI-driven systems for facial recognition in an office setting and applied machine learning to automation and security challenges in smart cities.
Skills
Estimation & Control
EKF / UKF
Impedance Control
MuJoCo
IsaacSim
ROS2
Gazebo
MATLAB
Perception
SLAM
Visual-Inertial Odometry
Computer Vision
Sensor Fusion
ORBSLAM3
Languages
Python
C++
Rust
Verilog
Development
React Native
Next.js
Expo
Supabase
Docker
Beyond the Lab
Multilingual in Arabic, English, and French. I grew up in Egypt, did research in Graz (Austria), studied briefly in Edinburgh, and now pursue my MS at Northeastern in Boston. Outside research I build apps, follow AI governance closely, and spend time with communities working at the intersection of robotics and policy.